Vector basics (position, displacement vectors, components, ijk, vector algebra, magnitude): notes and practice questions
- Scalars have magnitude only; vectors have both magnitude and direction.
- Vectors can be represented as directed line segments or component forms (column or base vectors ).
- Position vectors originate from the origin; displacement vectors connect two points (Destination - Origin).
- Magnitude is the length of a vector, calculated using the Pythagorean theorem.
- Vector addition/subtraction involves combining corresponding components.
- Scalar multiplication scales a vector's magnitude and potentially reverses its direction.
- Parallel vectors are scalar multiples of each other.
- A unit vector has a magnitude of 1 and is found by dividing a vector by its magnitude.
How it is examined
in that order is the single most common slip. "Proofs of geometrical properties using vectors" is real content, so a `Prove` question about a midpoint or a parallelogram is in scope. 4 to 7 marks.
The magnitude formula is given.
- Concept of a vector; position vectors; displacement vectors.
- Representation of vectors using directed line segments.
- Base vectors , , .
- Components of a vector: .
Linking questions
- Links to other subjects: vectors, scalars, forces and dynamics (physics).
- Link to complex numbers (AHL 1.12), which share the plane.
Practice questions
21 questions · 9 medium · 12 hardQuestion 1
MediumPaper 2 · calculator6 marksA drone is programmed to fly between three waypoints in a 3D space. The coordinates of the waypoints are given as P1(3, 7, 2), P2(8, 4, 10), and P3(1, 9, 5).
(a) Calculate the distance the drone travels from waypoint P1 to waypoint P2.
(b) Calculate the angle formed by the drone's path at waypoint P2 (i.e., the angle P1P2P3). Give your answer in radians to three significant figures.
Recall the formula for the distance between two points and in 3D space.
To find the angle between two paths meeting at P2, consider the vectors and . Use the dot product formula .
Question 2
HardPaper 1 · no calculator19 marksTwo spacecraft, S1 and S2, travel along straight paths, represented by the lines and respectively. The paths of the spacecraft intersect at a docking station D. A probe is located at a point P on the path of . This is shown in the following diagram.
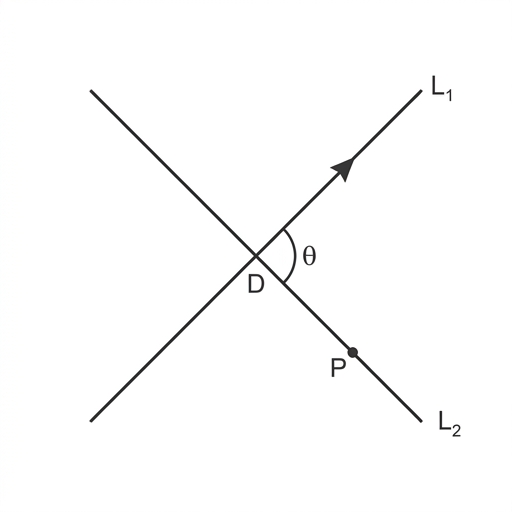
The direction vector of is . The vector is given by , where .
The acute angle between the paths and is , where .
(a) Show that .
(b) Find the value of .
(c) Hence, find the shortest distance from the probe at P to the path .
The paths and lie on a plane, .
(d) Find a vector normal to the plane .
A satellite dish is modelled as a right circular cone with its vertex at V. The base of the cone lies in the plane and is centred at P. The path is tangent to the circular base of the cone. The volume of the cone is cubic units. The position vector of P is .
(e) Find the two possible position vectors for V.
Use the scalar product formula for the angle between two vectors, .
Square both sides of the equation from part (a) to eliminate the square root, then solve the resulting quadratic equation.
The shortest distance from a point P to a line L1 can be found using trigonometry. Consider the right-angled triangle formed by P, D, and the point on L1 closest to P. The distance is given by . Alternatively, use the vector product formula for the distance.
A normal vector to a plane containing two lines can be found by taking the vector product of their direction vectors.
The radius of the cone's base is the shortest distance from P to L1. Use the volume formula to find the cone's height, . The vertex V is located at a distance from the centre P, along the direction of the normal vector to the plane. Remember there are two possible directions along the normal.
Question 3
MediumPaper 2 · calculator6 marksA geological survey is being conducted in a mountainous region. Three sensor stations, A, B, and C, are set up at different locations. Their coordinates, relative to a central reference point (in meters), are given as:
Station A:
Station B:
Station C:
(a) Find the distance between Station A and Station B.
(b) Find the size of the angle (the angle at Station B).
To find the distance between two points and in 3D space, use the distance formula: . Alternatively, find the displacement vector between the two points and then calculate its magnitude.
To find the angle between three points A, B, and C (angle at B), you can use the dot product of vectors and . Remember the formula . Alternatively, you can use the cosine rule if you find all three side lengths of triangle ABC.
Question 4
HardPaper 1 · no calculator21 marksThe plane has equation .
(a) Show that the point lies on the plane .
The plane is given by , where and .
(b) In the case where , is perpendicular to and point A lies on . Given that , find the value of and the value of .
For parts (c), (d) and (e) it is now given that is parallel to .
(c) Given that , determine the value of .
It is also given that .
The line through A that is perpendicular to meets at the point B.
(d) (i) Find the coordinates of B.
(ii) Hence, find the perpendicular distance between and .
(e) Find the equation of a third parallel plane which is also a perpendicular distance of from .
To show that a point lies on a plane, substitute the coordinates of the point into the equation of the plane and verify that the equation holds true.
Recall the condition for two planes to be perpendicular in terms of their normal vectors. The dot product of the normal vectors must be zero. After finding the value of 'a', use the fact that point A lies on to find 'd'.
For two planes to be parallel, their normal vectors must be scalar multiples of each other. Set up a proportionality relationship between the components of the normal vectors.
First, write down the vector equation of the line passing through point A. The direction vector of this line is the normal vector of plane . Then, find the point of intersection of this line with plane by substituting the parametric equations of the line into the equation of the plane.
The perpendicular distance between the two parallel planes is the distance between point A (on ) and point B (on ). Calculate the magnitude of the vector .
The plane is on the opposite side of from . Point A is on . You found point B on by moving from A along the normal vector. To find a point C on , you need to move from A in the opposite direction by the same distance.
Question 5
MediumPaper 2 · calculator18 marksTwo automated guided vehicles (AGVs), AGV-1 and AGV-2, are moving along straight paths in a 3D warehouse. The path of AGV-1 is given by the vector equation where .
The path of AGV-2 is given by the vector equation where .
All coordinates are in meters.
(a) Show that the paths of AGV-1 and AGV-2 intersect at a point P and find the position vector of P.
(b) A safety sensor plane is installed in the warehouse. The plane is given by the equation . Verify that the paths of both AGV-1 and AGV-2 lie entirely within this safety sensor plane .
(c) An emergency charging station is located at point Q with position vector .
(i) A charging drone is dispatched from Q and travels along a path perpendicular to the plane . This drone lands on the plane at point R. Find the position vector of R.
(ii) Calculate the shortest distance from the emergency charging station Q to the safety sensor plane .
(d) Due to a system malfunction, AGV-1 needs to be redirected to a virtual point Q' which is the reflection of the emergency charging station Q in the plane . Find the position vector of Q'.
To show that two lines intersect, you need to find values for the parameters (s and t) that satisfy all three component equations. Then, substitute these parameters back into one of the vector equations to find the intersection point.
For a line to lie entirely within a plane, two conditions must be met: the direction vector of the line must be perpendicular to the normal vector of the plane, and any point on the line must satisfy the plane's equation.
The line from Q to R is perpendicular to the plane, so its direction vector is the normal vector of the plane. Find the equation of this line, then find its intersection with the plane .
The shortest distance from point Q to the plane is the magnitude of the vector QR, where R is the projection of Q onto the plane.
The point R (found in part c.i) is the midpoint of the line segment QQ'. Use the midpoint formula to find the coordinates of Q'.
Question 6
HardPaper 1 · no calculator9 marksThe diagram shows a triangle OXY with and .
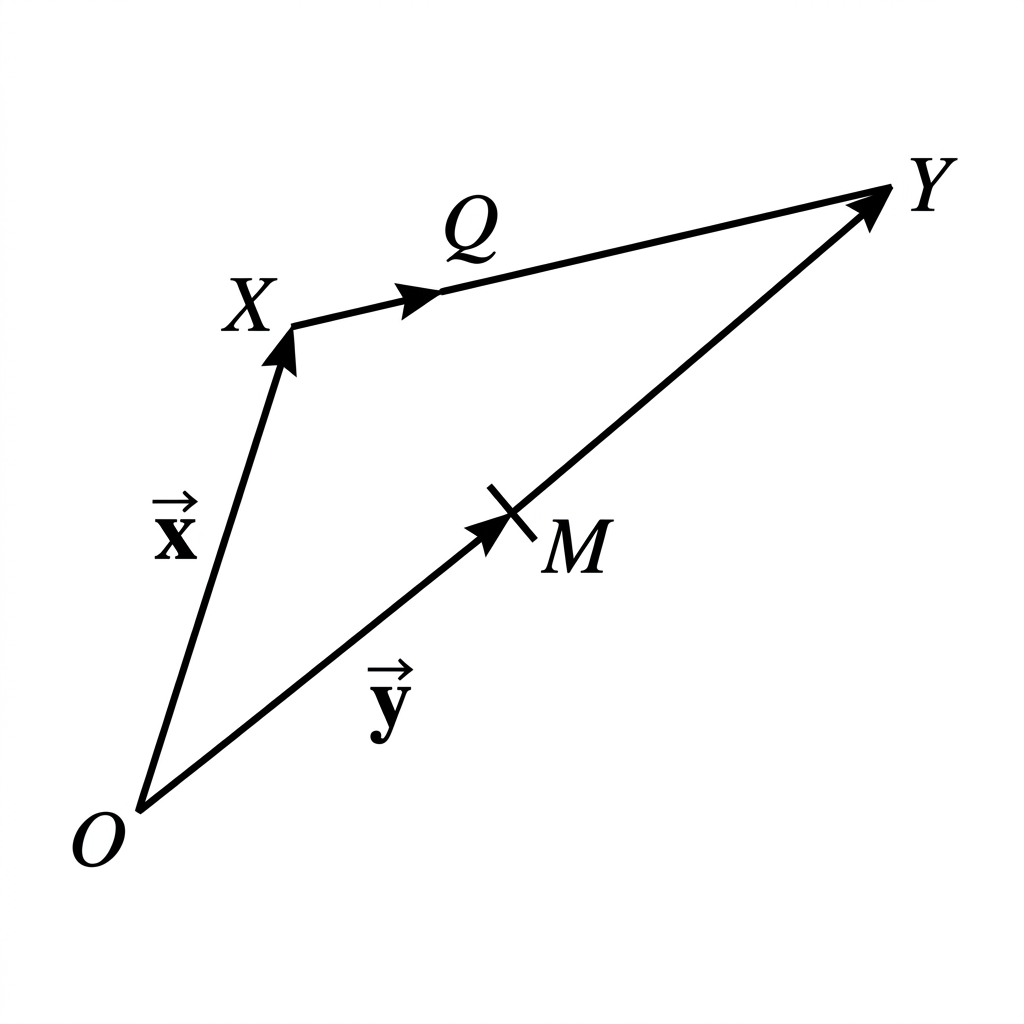
The point M is the midpoint of OY. The point Q lies on the line segment (XY) such that , where .
(a) Show that .
(b) It is given that , and the angle between vectors and is .
In the case that is perpendicular to , find the value of .
Express the vector as a difference of two position vectors, for example . Then find expressions for and in terms of and .
What is the value of the scalar product of two perpendicular vectors? Use this property for and . You will first need to calculate the value of using the formula involving magnitudes and the angle between the vectors.
Question 7
MediumPaper 2 · calculator9 marksA landscape architect is designing a triangular shade sail for a patio. The vertices of the sail are defined by points A, B, and C in a 3D coordinate system, where the z-axis represents height.
The coordinates of the vertices are A, B and C, where is a positive constant representing a design parameter.
(a) Show that the vector product is given by .
(b) The architect wants to minimize the tension in the sail, which is proportional to the magnitude of the vector product of two adjacent sides. Find the smallest possible value of .
(c) Calculate the smallest possible area of the shade sail.
First, find the displacement vectors and . Then, use the formula for the cross product of two vectors.
To find the minimum magnitude, consider the square of the magnitude, . This will result in a polynomial in . You can then use calculus (finding the derivative and setting it to zero) or a GDC to find the minimum value for .
The area of a triangle formed by two vectors is half the magnitude of their cross product.
Question 8
HardPaper 1 · no calculator19 marks(a) The line passes through the point Q(2, 0, 5) and has a direction vector .
Write down a vector equation for .
(b) A second line, , passes through the points C(3, 1, 0) and D(4, 3, -2).
Find a vector equation for .
(c) Show that and are skew.
(d) Find in terms of , where M is a general point on .
(e) Hence, find the coordinates of the point M on that is closest to Q.
(f) The origin is denoted by O(0, 0, 0). Find the equation of the plane that contains the points O, Q and the point M found in part (e). Give your answer in the form , where .
The vector equation of a line is given by , where is the position vector of a point on the line and is the direction vector of the line.
To find the vector equation of a line passing through two points, first find the direction vector by subtracting the position vectors of the two points. Then use one of the points as the position vector in the equation.
To show that two lines are skew, you must demonstrate two things: they are not parallel, and they do not intersect. Check if their direction vectors are scalar multiples of each other. Then, set the vector equations equal to each other and try to solve the resulting system of linear equations.
First, express the position vector of a general point M on using the parameter . Then find the vector by subtracting the position vector of Q from the position vector of M. Finally, calculate the scalar (dot) product of and the direction vector of , which is .
The point M on closest to Q is such that the vector is perpendicular to the direction vector of . This means their scalar product is zero. Use your result from part (d).
To find the equation of a plane, you need a point on the plane and a normal vector. You have three points (O, Q, M). You can form two vectors in the plane, for example and . The normal vector to the plane is perpendicular to both of these vectors, so you can find it by calculating their vector (cross) product.
Question 9
MediumPaper 1 · no calculator6 marksA modern art sculpture is in the shape of a tetrahedron with vertices at points P(2, 1, 0), Q(3, -1, 2), R(0, 2, 1), and S(4, 3, 5). The coordinates are given in metres relative to a fixed origin O.
Calculate the volume of the sculpture.
The volume of a tetrahedron with vertices A, B, C, and D can be found using the formula . First, find three vectors that share a common starting point, for example, , , and .
Question 10
HardPaper 2 · calculator20 marksThree points , and lie on the plane .
Find the vector and the vector .
Hence find the equation of , expressing your answer in the form , where .
Plane has equation .
The line is the intersection of and . Verify that the vector equation of can be written as .
The plane is given by . The line and the plane intersect at the point .
Show that at the point , .
Hence find the coordinates of .
The point lies on .
Find the reflection of the point in the plane .
Hence find the vector equation of the line formed when is reflected in the plane .
To find a vector between two points, subtract the coordinates of the initial point from the coordinates of the terminal point.
The cross product of two vectors lying in a plane gives a normal vector to the plane. Then use the formula where is the normal vector and is a point on the plane.
To verify the line equation, substitute the general point of the line into the equations of both planes. Both equations should hold true for any value of . Alternatively, check if the direction vector is perpendicular to the normal vectors of both planes and if the position vector lies on both planes.
Substitute the parametric equations of line into the equation of plane and solve for .
Substitute the value of found in part (d.i) back into the vector equation of line to find the coordinates of point .
Find the equation of the line passing through and perpendicular to . Find the intersection point of this line with (this is the midpoint between and its reflection ). Use the midpoint formula to find .
The reflected line passes through point (the intersection of and ) and the reflected point found in part (e.i). Find the direction vector using these two points.
Question 11
MediumPaper 1 · no calculator12 marksPoints P and Q have position vectors and respectively, relative to an origin O. Let M be the midpoint of the line segment [PQ].
Show that the position vector of M is .
A triangle has vertices P(1, 0, 2), Q(3, 4, -2), and R(5, 2, 6).
Let L, M and N be the midpoints of the sides [PQ], [QR] and [RP] respectively. Find the position vectors of L, M and N.
The centroid G of the triangle PQR has position vector .
Find the coordinates of G.
Show that the points P, G, and M are collinear, where M is the midpoint of [QR].
Hence, find the ratio PG:GM.
Consider the vector path from O to M. You can go directly, or via P. How can you express the vector in terms of the vector ?
Recall the midpoint formula that you just proved in part (a). Apply it to the position vectors of the vertices of the triangle.
The position vectors , , and are given by the coordinates of the points P, Q, and R. Substitute these into the given formula for the centroid.
To show three points are collinear, you can show that the vector connecting the first two points is a scalar multiple of the vector connecting the first and third points. For example, show that for some scalar .
The relationship between the vectors you found in part (d), and , directly tells you the ratio. If , what does this mean about the position of G on the line segment PM?
Question 12
HardPaper 2 · calculator20 marksTwo drones, Drone X and Drone Y, have position vectors with respect to an origin O given respectively by
where represents the time in minutes and .
Entries in each column vector give the displacement east of O, the displacement north of O and the distance above sea level, all measured in kilometres.
(a) Find the three-figure bearing on which Drone Y is travelling.
(b) Show that Drone X travels at a greater speed than Drone Y.
(c) Find the acute angle between the two drones' lines of flight. Give your answer in degrees.
The two drones' lines of flight cross at point P.
(d) (i) Find the coordinates of P.
(ii) Determine the length of time between the first drone arriving at P and the second drone arriving at P.
(e) Let represent the distance between Drone X and Drone Y for .
Find the minimum value of .
The bearing is determined by the horizontal components (East and North) of the direction vector. Remember bearings are measured clockwise from North.
The speed of a drone is the magnitude of its direction vector.
Use the dot product formula for the angle between two vectors: . Remember to find the acute angle.
Set the two vector equations equal to each other, using different time parameters for each drone (e.g., and ). Solve the resulting system of equations.
The time values you found in part (d)(i) represent when each drone arrives at P. Find the difference between these times.
First, find the vector representing the displacement between the two drones, . Then, find the magnitude of this vector, . To minimize , it's often easier to minimize . Use calculus (derivative) to find the minimum.
Question 13
MediumPaper 2 · calculator10 marksA drone's initial flight path from its base station at the origin is represented by a displacement vector . Let , , and be the angles that makes with the positive -axis, -axis, and -axis respectively.
Show that .
If the drone's initial displacement vector is meters, calculate the angles , , and to one decimal place.
A security laser beam is emitted from the base station (origin) along a direction perpendicular to the drone's initial flight path. Show that the equation of the plane containing this laser beam can be expressed in the form , where , , and are the angles found in part (b).
Consider the dot product of the vector with the unit vectors , , and . Recall that . What is the magnitude of the unit vectors?
First, calculate the magnitude of the vector . Then use the formulas for the direction cosines: , , . Remember to use the inverse cosine function to find the angles in degrees.
A plane passing through the origin has the general equation . The vector is the normal vector to the plane. How is the normal vector related to the direction of the drone's flight path?
Question 14
HardPaper 2 · calculator9 marks(a) A deep-sea submersible is navigating a complex underwater current system. Its primary thruster provides a force vector N. It is also affected by a secondary current, which exerts a force with a magnitude of 10 N.
Find the possible range of values for the magnitude of the resultant force .
(b) Given that the magnitude of the resultant force is a minimum, find the resultant force vector.
(c) A third, unknown current exerts a force N, where . Find such that its magnitude is equal to the magnitude of and it acts perpendicularly to .
The magnitude of the resultant of two vectors is maximized when they are in the same direction and minimized when they are in opposite directions. Consider the triangle inequality for vectors.
For the magnitude of the resultant force to be a minimum, the two force vectors must be acting in opposite directions. The resultant vector will be in the direction of the larger force.
If two vectors are perpendicular, their scalar (dot) product is zero. Also, remember the condition that both components of must be positive.
Question 15
MediumPaper 1 · no calculator6 marksA flat rectangular mirror is mounted on a wall. In a 3D coordinate system, with the origin at a corner of the room, the mirror lies on a plane .
One of the edges of the mirror is represented by the line with equation .
The plane also contains the point P.
Find the Cartesian equation of the plane .
To find the equation of a plane, you need a point on the plane and a vector normal (perpendicular) to the plane. You are given one point P. Can you find another point on the plane from the line equation? The direction vector of the line is parallel to the plane. How can you find a second vector parallel to the plane? The cross product of two vectors parallel to the plane will give you the normal vector.
Question 16
HardPaper 1 · no calculator15 marksConsider the points given by the coordinates , , .
Find the vector .
Hence, find the exact area of triangle PQR.
Show that the Cartesian equation of the plane , which contains the triangle PQR, is .
A second plane is given by the equation . Find a vector equation for the line of intersection of the planes and .
First, find the position vectors and by subtracting the coordinates of the initial point from the terminal point. Then, compute their cross product, for example by using the determinant formula for a matrix.
The area of a triangle formed by two vectors is half the magnitude of their cross product. Use the result from part (a).
The cross product vector found in part (a) is a normal vector to the plane. Use this normal vector and the coordinates of one of the points (P, Q, or R) to determine the equation of the plane.
To find the line of intersection, you need to solve the system of equations for the two planes. You can set one variable, say , equal to a parameter . Alternatively, the direction vector of the line of intersection can be found by taking the cross product of the normal vectors of the two planes.
Question 17
MediumPaper 2 · calculator5 marksTwo drones, X and Y, are flying over a large, flat field. Their positions are monitored from a control tower at the origin (0, 0, 0). At time minutes after 10:00 am, their position vectors, with distances in metres, are given by:
Find the minimum distance between the two drones.
The distance between the two drones can be represented by the magnitude of their relative position vector, . Find an expression for this distance as a function of time, , and then find the minimum value of this function using your GDC.
Question 18
HardPaper 2 · calculator13 marksTwo drones, Drone Alpha and Drone Beta, are flying in a 3D space. At a particular instant, Drone Alpha passes through point and then point .
(a) Find a vector equation of the line representing Drone Alpha's path.
At the same instant, Drone Beta passes through point and then point .
(b) Find a vector equation of the line representing Drone Beta's path.
(c) Hence, or otherwise, find the shortest distance between the paths of Drone Alpha and Drone Beta.
Recall that a vector equation of a line can be expressed as , where is the position vector of a point on the line and is the direction vector of the line.
Similar to part (a), identify a position vector and a direction vector for Drone Beta's path.
The shortest distance between two skew lines and is given by the formula .
Question 19
HardPaper 1 · no calculator11 marksA plane has the Cartesian equation . A point B has coordinates .
(a) Find the vector equation of the line that passes through the point B and is perpendicular to the plane .
(b) Find the coordinates of the point of intersection, N, of the line and the plane . Hence, find the exact distance between the point B and the plane .
(c) The point P has coordinates .
Show that the distance between the point P and the plane is given by
The direction vector of a line perpendicular to a plane is the same as the normal vector of the plane. How can you find the normal vector from the plane's equation?
First, write the equation of the line in parametric form. Then, substitute these parametric equations into the equation of the plane to find the value of the parameter at the point of intersection.
You can follow the same procedure as in part (b), but use the general point instead of . Alternatively, consider the scalar projection of the vector from any point on the plane to P onto the normal vector of the plane.
Question 20
HardPaper 2 · calculator21 marksConsider the non-zero vectors and . Let be the angle between and .
Using the definitions of and in terms of , and , show that .
A triangle PQR has vertices P(1, 0, 1), Q(, 2) and R(4, 1, 1), where .
The vectors and are defined as and .
It is given that and the area of triangle PQR is square units.
Find the value of .
Hence, or otherwise, find the value of .
Hence, or otherwise, find the possible values of and the corresponding values of .
Consider a new point S, the vector is defined as .
It is given that and , and the area of triangle PRS is 10 square units.
Assuming that , find the possible vectors for .
Recall the definitions of the dot product and the magnitude of the cross product in terms of the magnitudes of the vectors and the angle between them. Use the Pythagorean identity for trigonometric functions.
The area of a triangle formed by two vectors is half the magnitude of their cross product.
Use the identity from part (a) and the values you've found for the dot product and the magnitude of the cross product. Remember to calculate the magnitude of first.
Express in terms of and . Set up two equations using the given dot product and the magnitude of found in the previous part. Solve the system of equations.
If is perpendicular to both and , it must be parallel to their cross product. The area of triangle PRS can be found using the magnitude of and and the angle between them.
No question on this page matches those filters. Try another difficulty or paper.
1 more Vector basics (position, displacement vectors, components, ijk, vector algebra, magnitude) question in the app
Every answer is marked mark by mark, IB-style, and the AI tutor helps when you are stuck.
Where marks are lost
- Using your own wrong value after failing a "show that".